Maritime Counter-Drone: From Superyachts to Commercial Shipping and Offshore Energy
Oct 15 2026
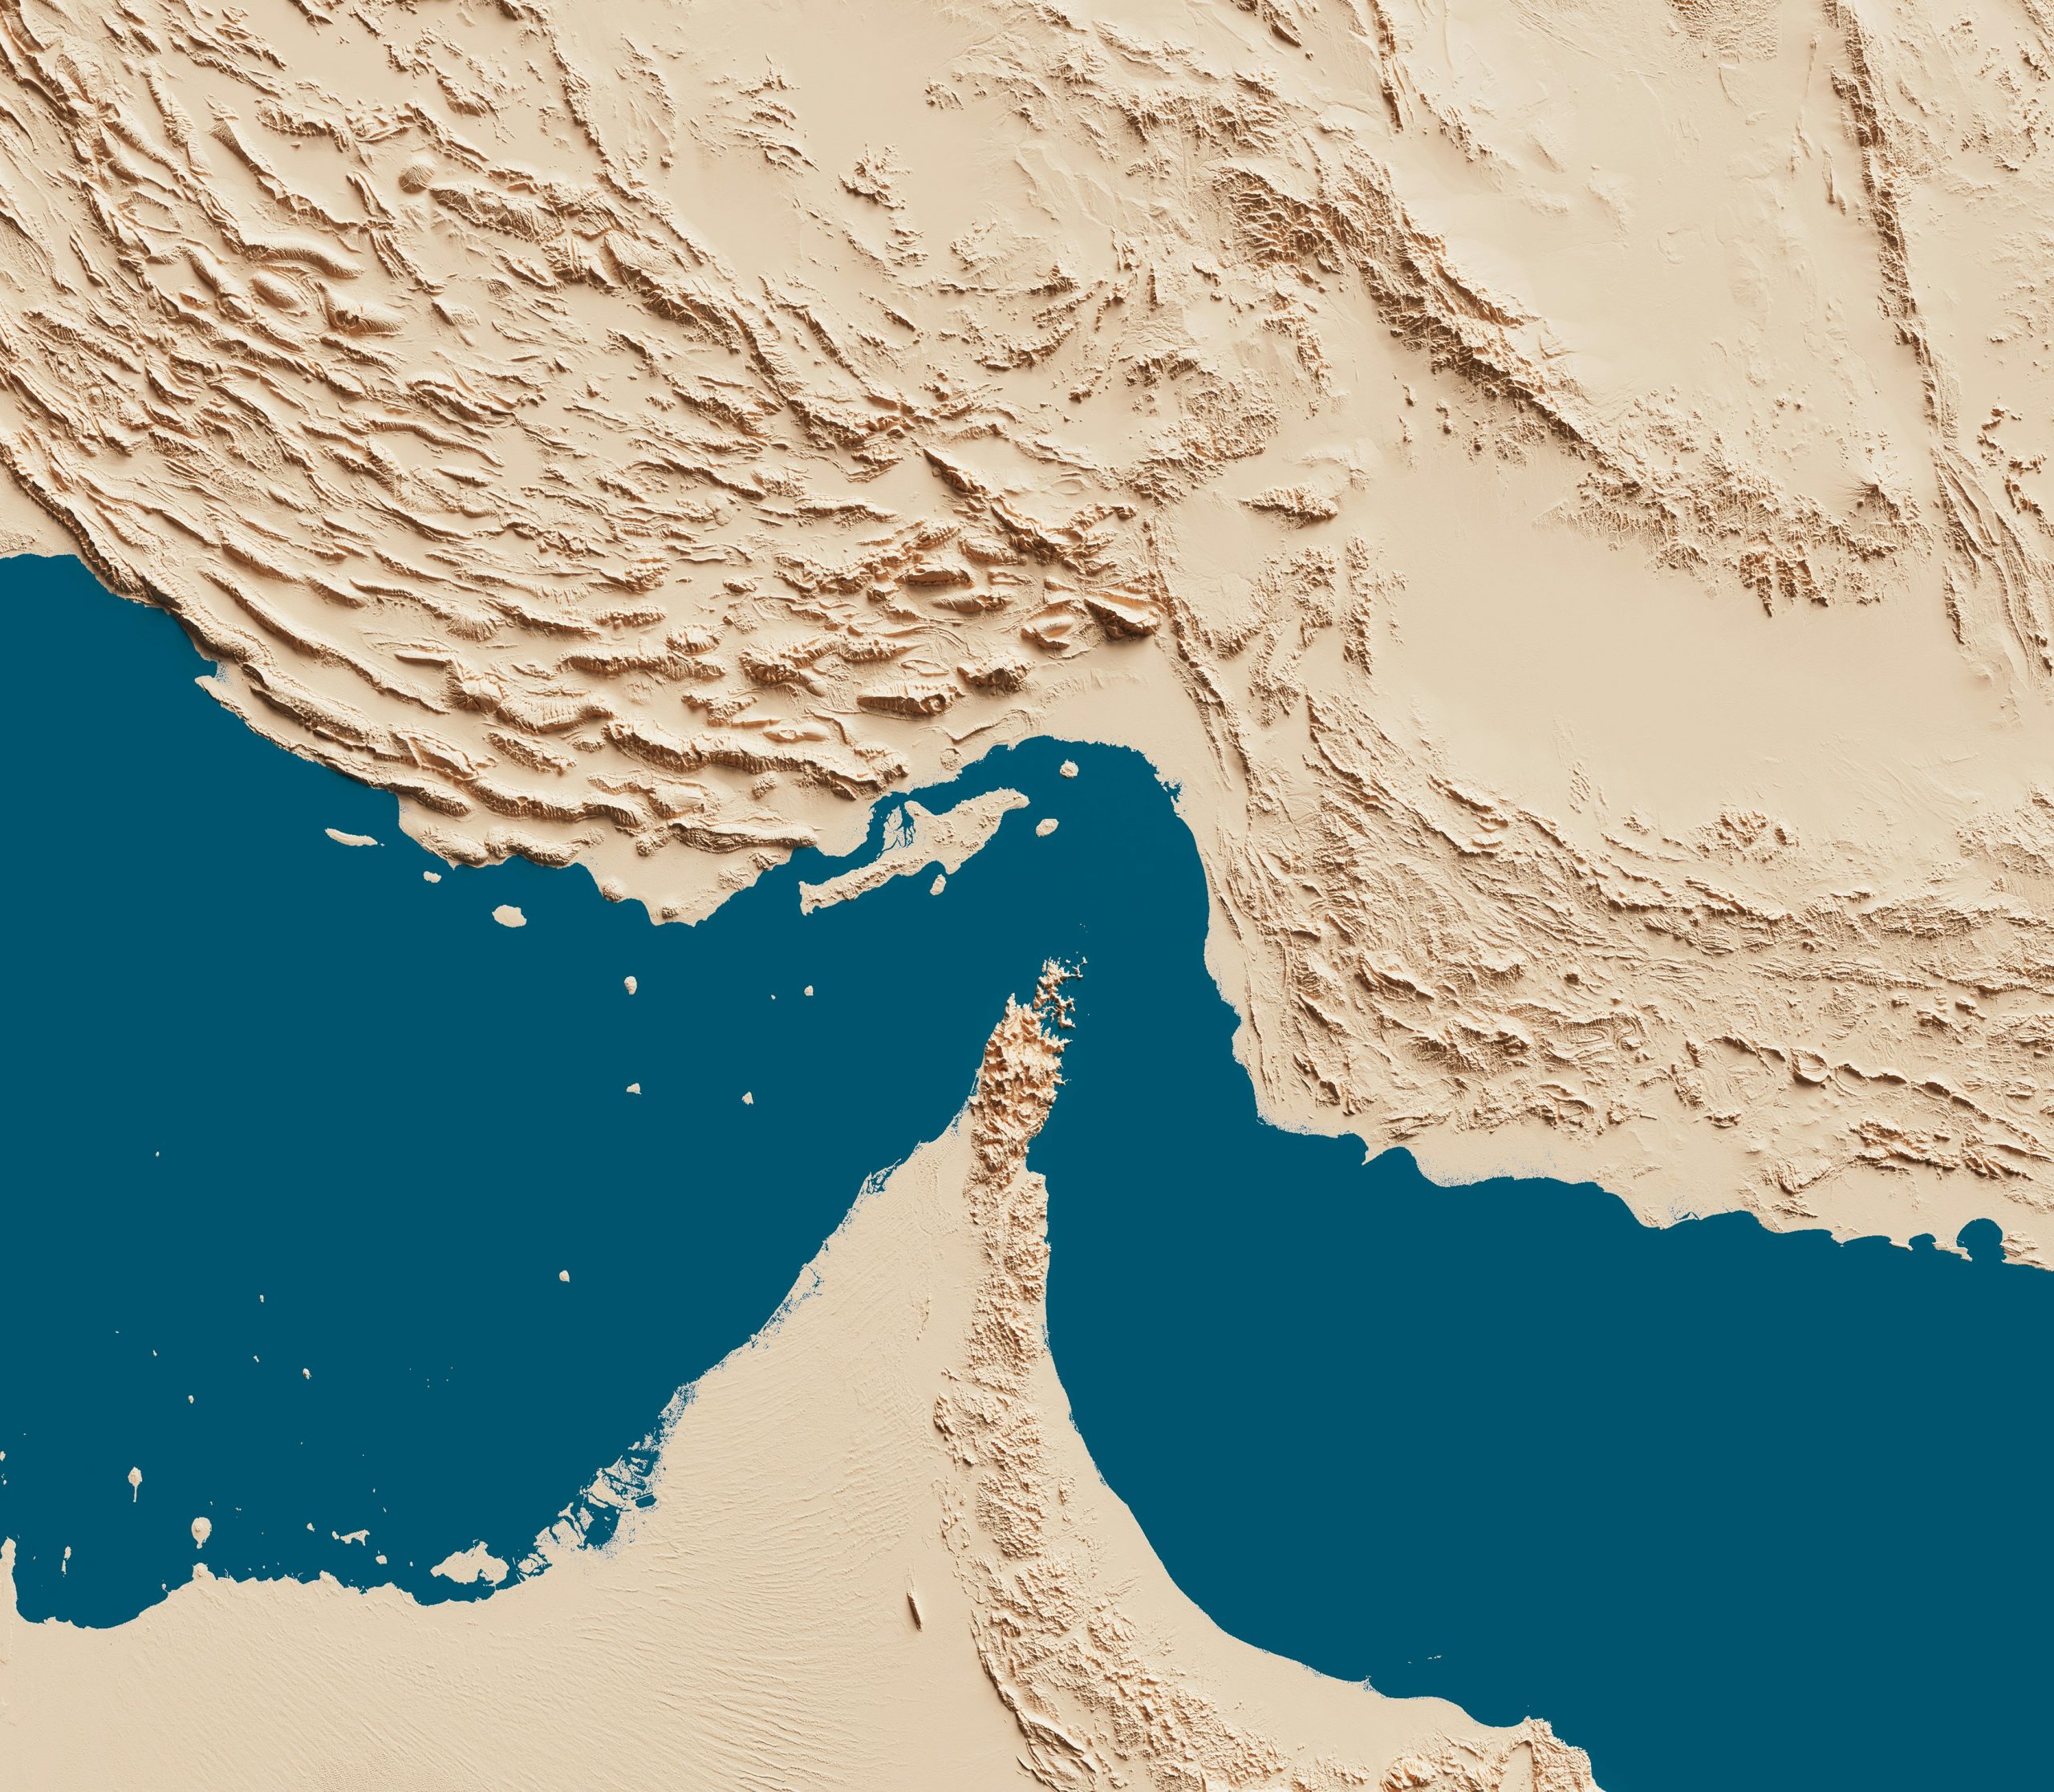
Between September 28 and October 5, 2026, maritime security monitors recorded at least twelve attacks, attempted attacks, or harassment incidents against tankers, LNG carriers, and LPG carriers in the waters around the Strait of Hormuz, the highest weekly total for that waterway in the current period of regional tension. The International Maritime Organization logged nine of them. One tanker was struck by an unidentified object, and twelve crew members were injured.
What makes that week significant is not only the count. It is what happened on the demand side in the days that followed. Maritime security providers reported a sharp rise in inquiries from shipowners, with oil and gas transport and offshore energy operators showing the strongest interest. For a market that spent years serving a narrow, high-end customer, that is a change of address. Maritime counter-drone is moving from the superyacht to the commercial fleet.
Why the Superyacht Model Does Not Carry Over
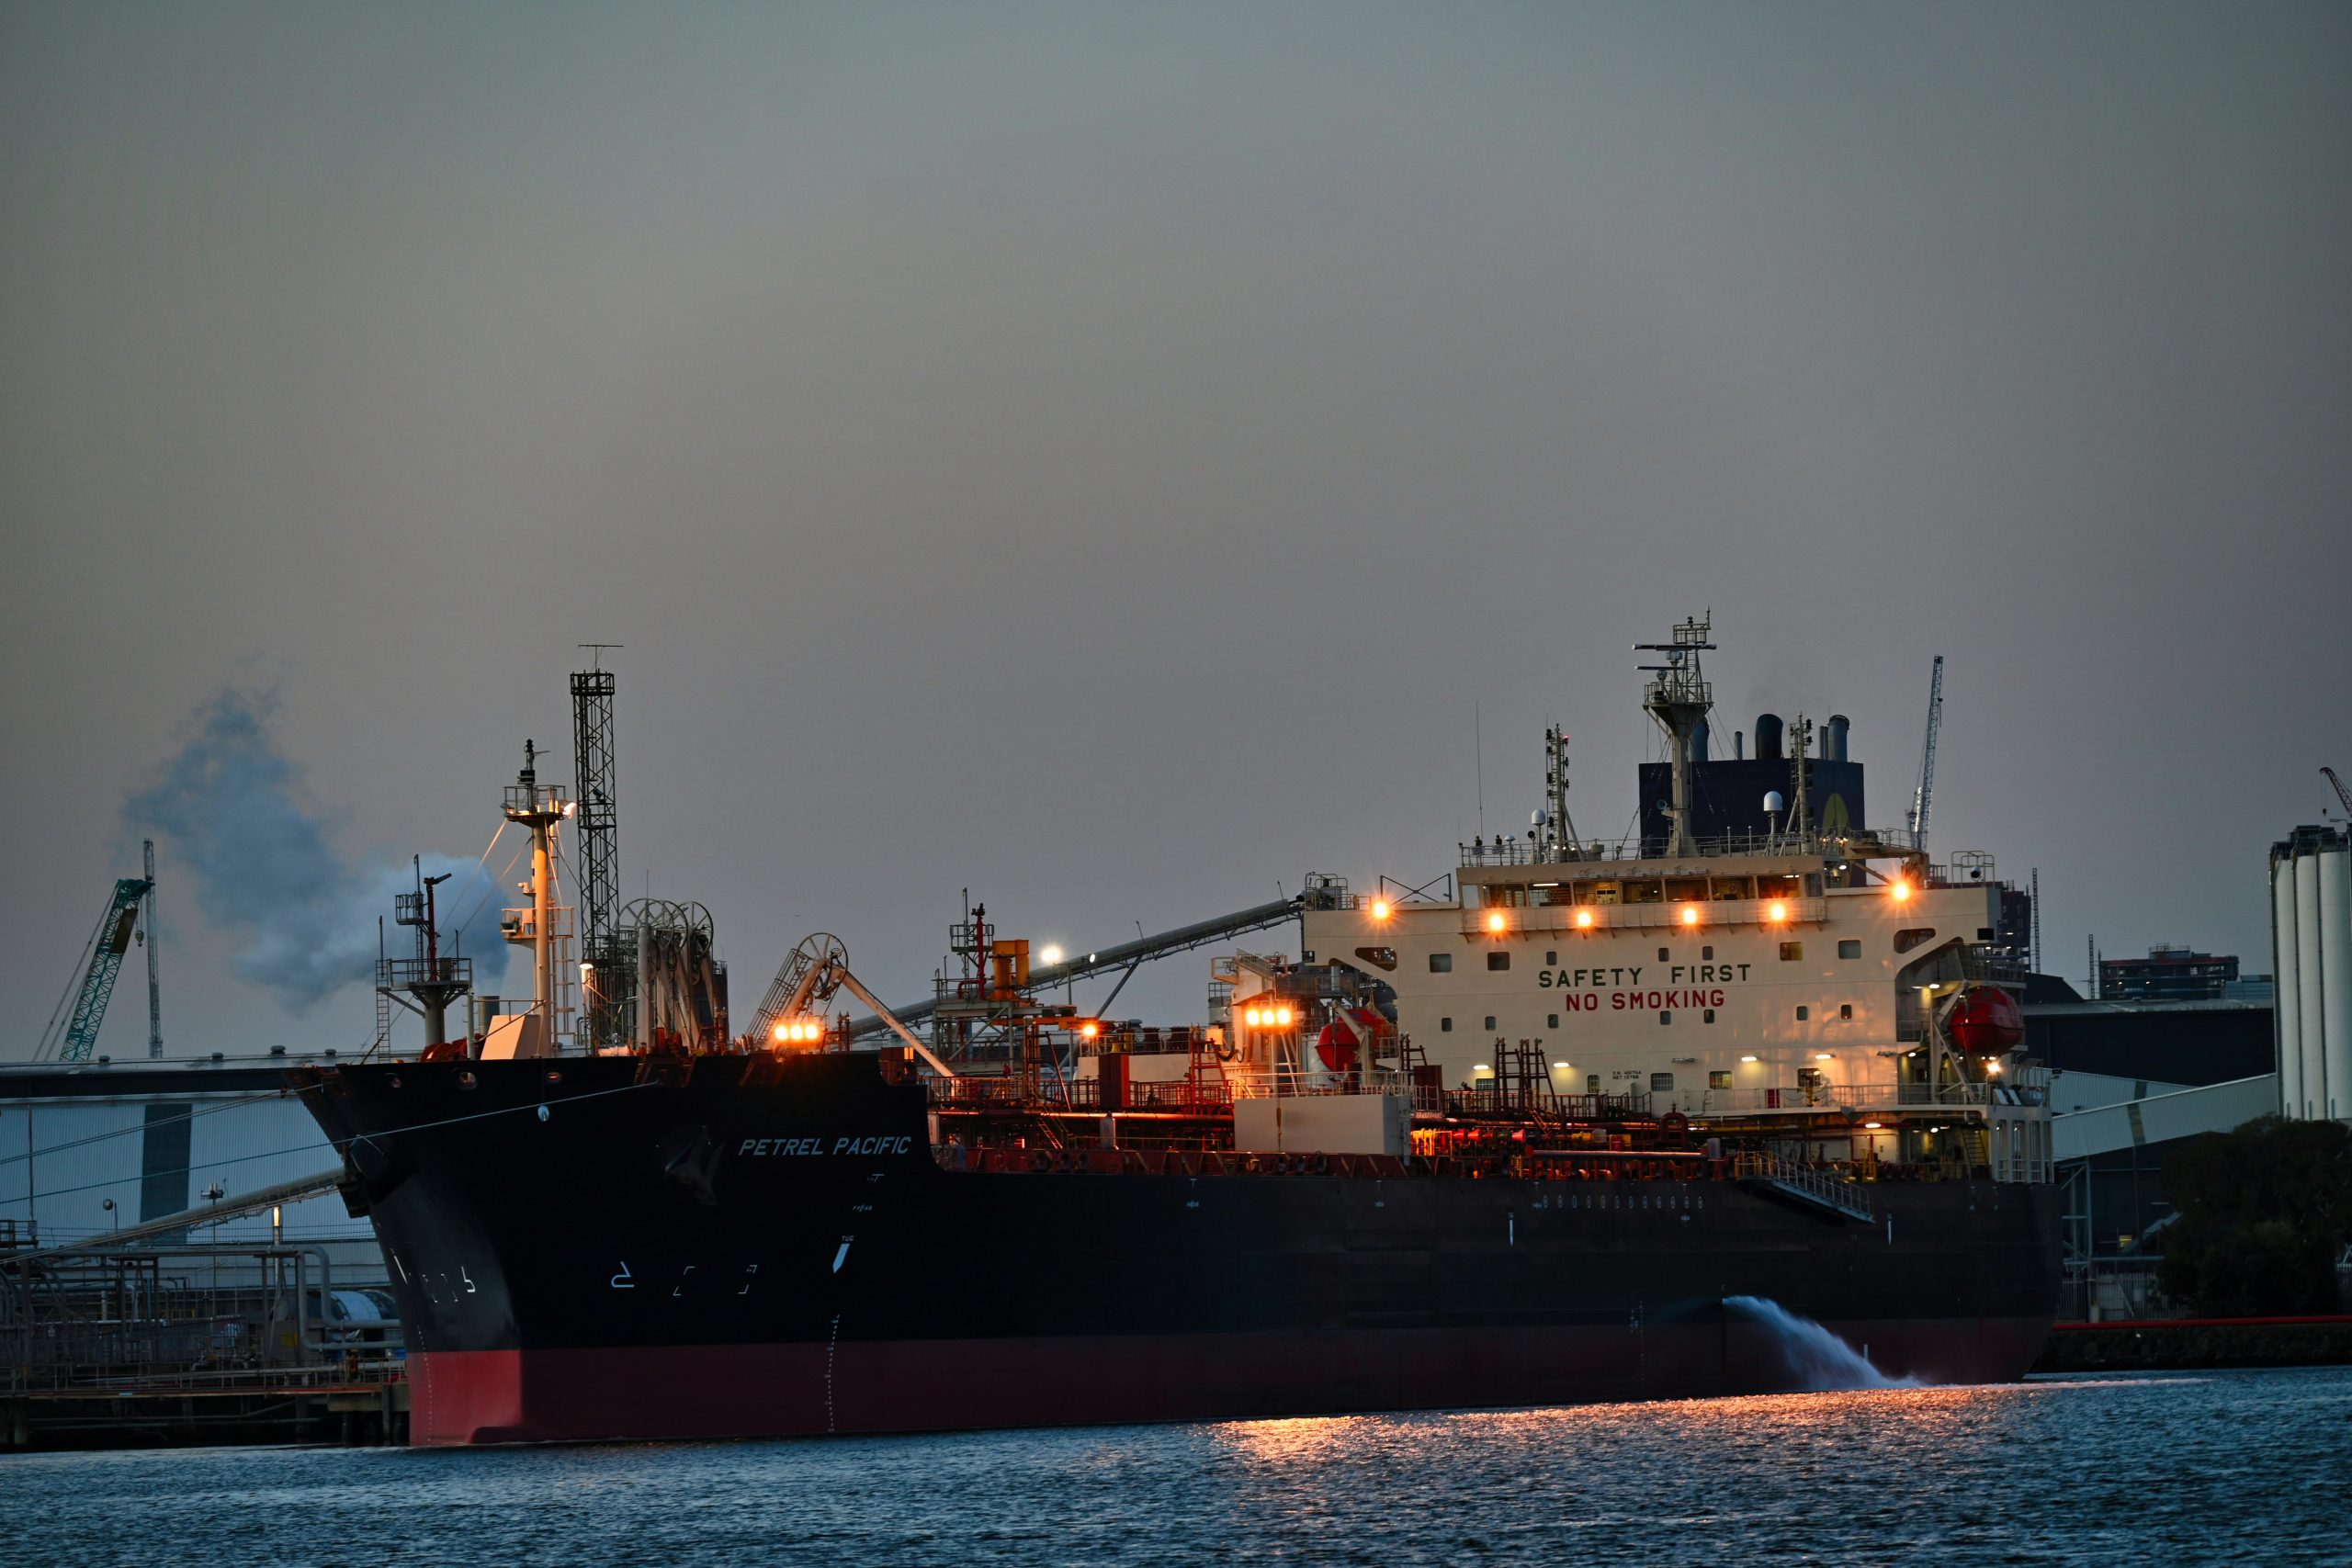
The first maritime counter-drone buyers were private owners, and the requirements that shaped the first generation of products came from that world. A superyacht has a small crew, a generous budget, and a strong preference for discretion. It can also be highly selective about where it sails. A system tuned for that customer optimizes for a compact footprint, a discreet installation, and a willingness to avoid difficult water when the risk rises.
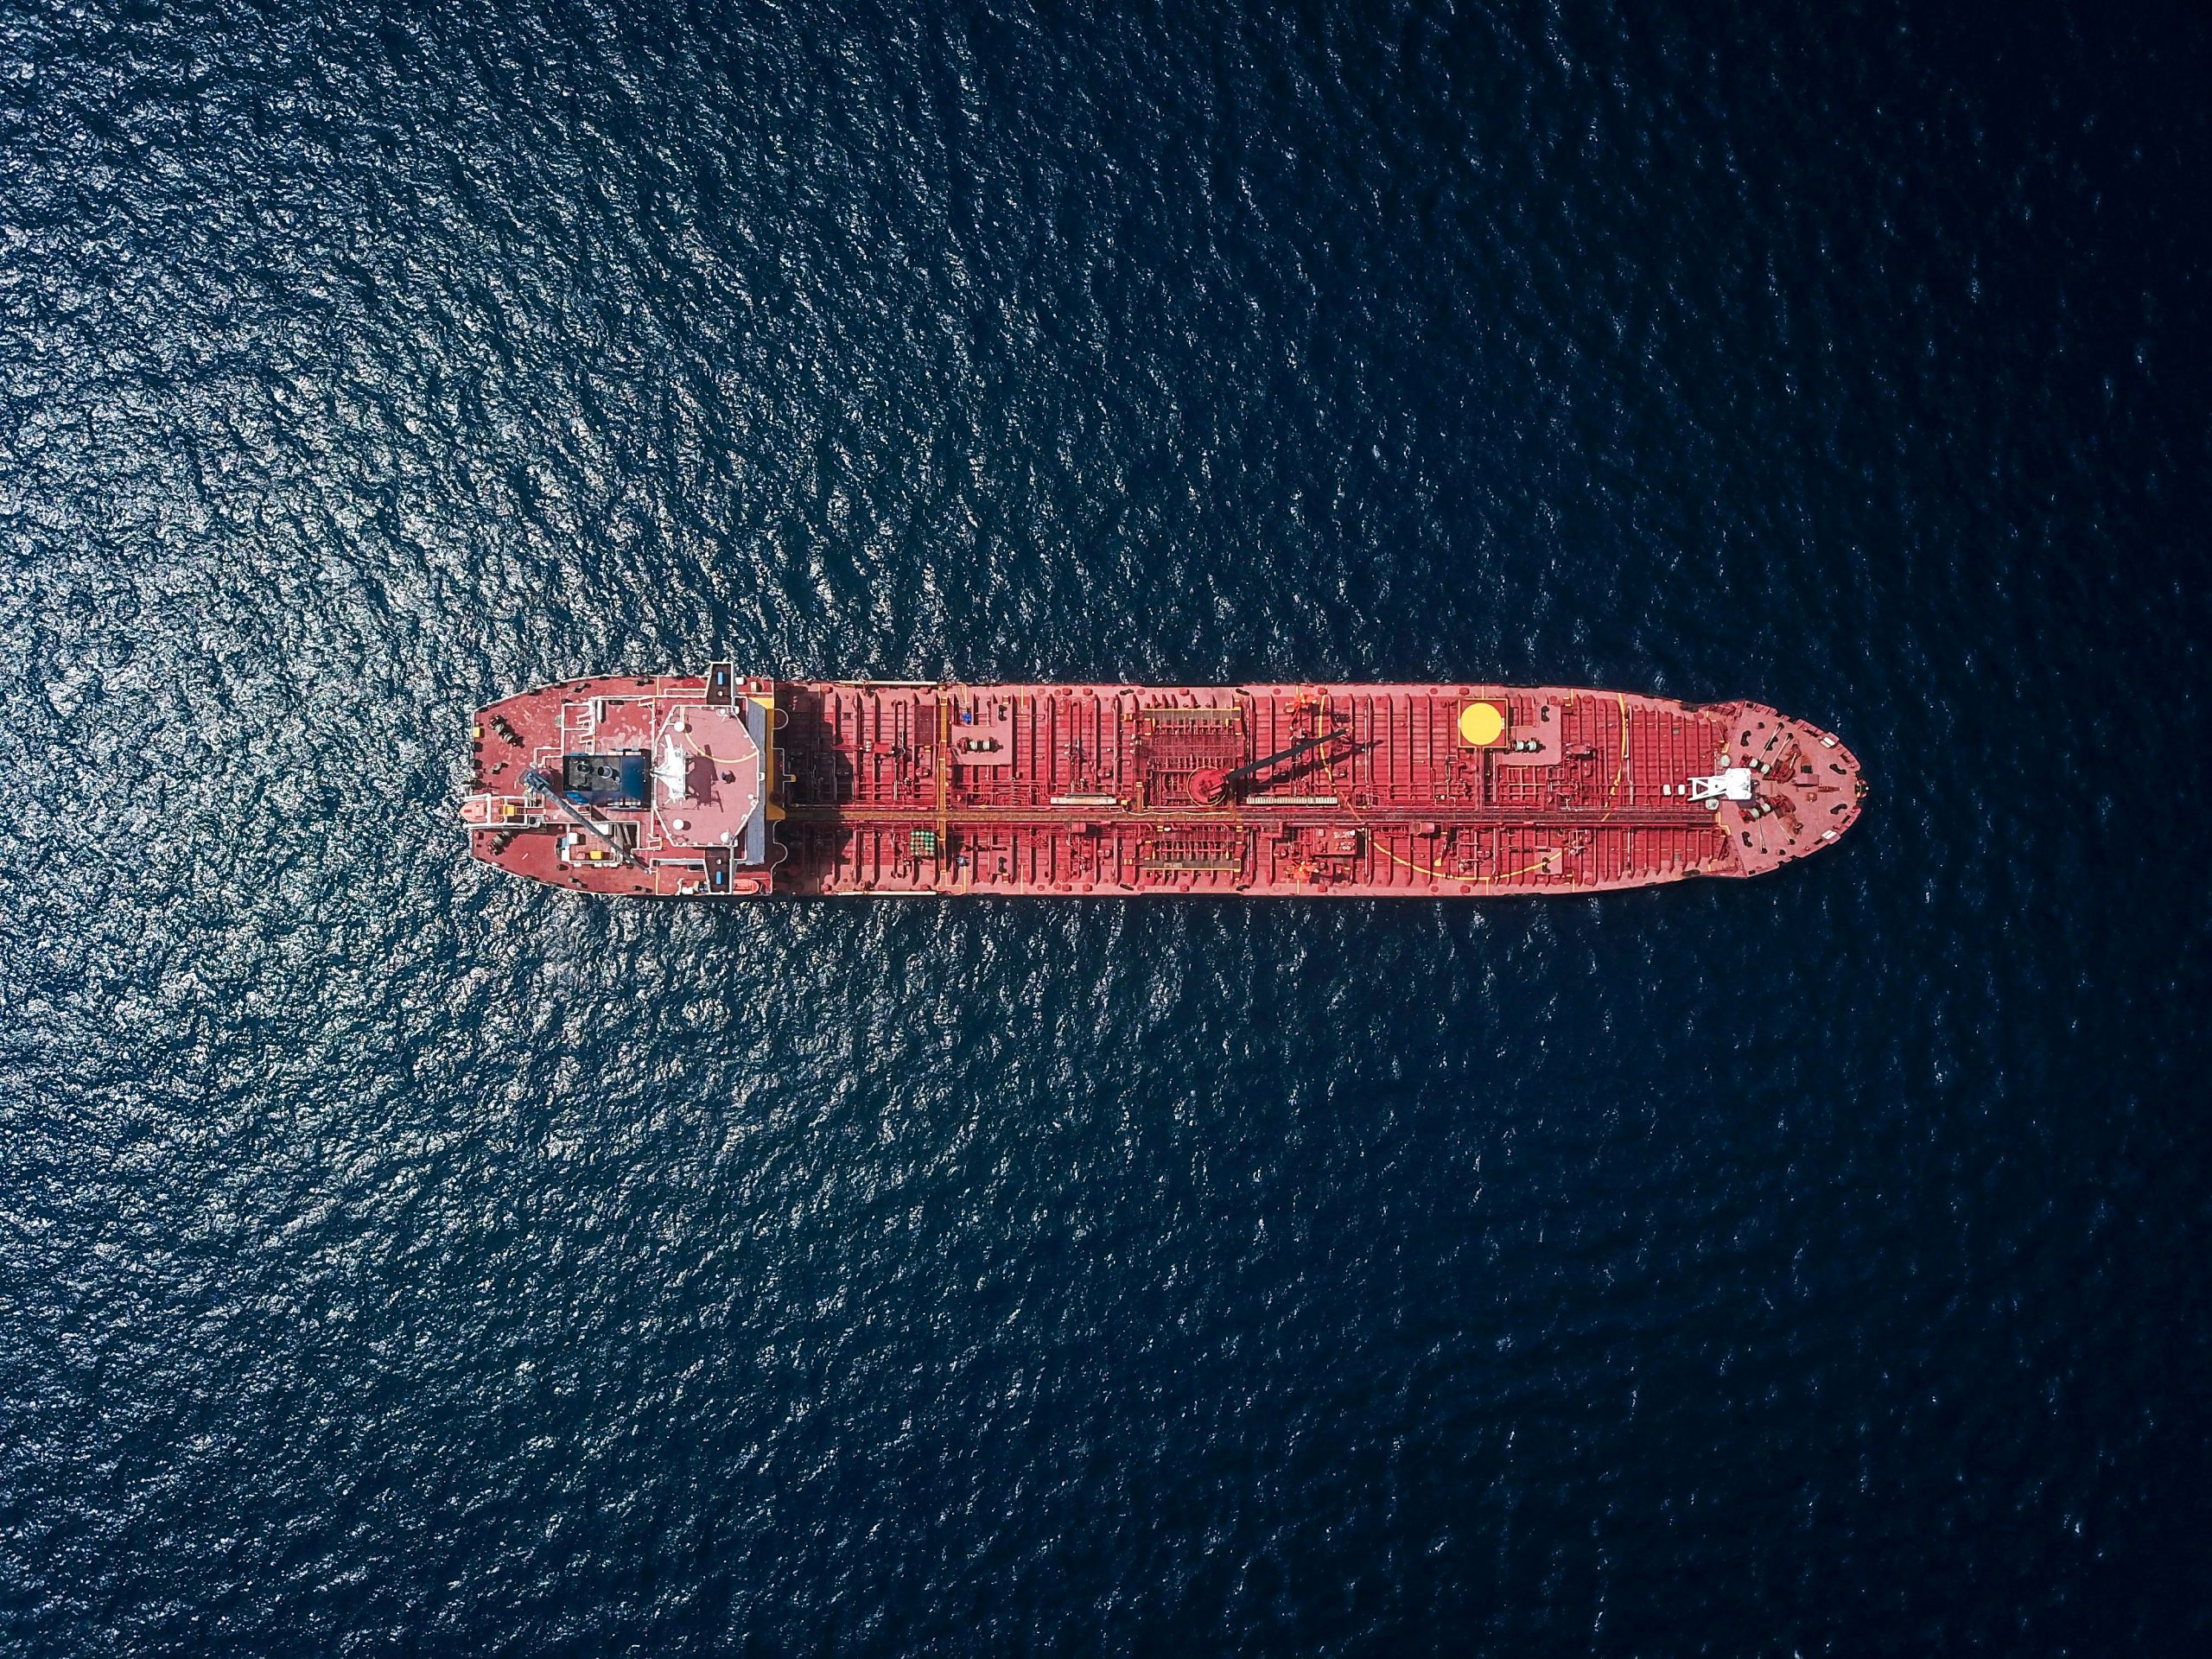
A commercial fleet has almost none of those conditions. The vessel is large, the crew is busy with its own work, the budget is scrutinized, and the route is set by a charter contract rather than by a security preference. A tanker that has to keep a schedule through a contested waterway cannot decide to go around it. The product that fits a superyacht is not the product that fits a very large crude carrier, and the gap between the two is where the current market is forming.
The commercial buyer also asks different questions. A private owner asks whether the system works. A shipping company asks who operates it, what it costs to run for five years, whether it can be transferred between vessels, and who is liable when it is used. Those questions move the design away from a single impressive capability and toward something a small crew can run in addition to its normal duties.
The Constraints a Moving Vessel Creates
A ship is a difficult sensor platform, and the reasons are physical before they are technical. Salt spray and constant humidity attack outdoor equipment. The deck is never still, so a sensor has to hold a track while its own reference frame keeps moving. The radio environment is dense with legitimate traffic, from port systems to navigation aids. And the airspace around a busy waterway is crowded with aircraft and small craft that must never be mistaken for a threat.
The regulatory picture adds a second layer of difficulty. A vessel crossing several jurisdictions passes through different rules on what may be transmitted and when. An action that is permitted in one stretch of water may be prohibited in the next, and a bridge crew has neither the time nor the legal standing to resolve that in the moment. This is the reason the design conversation in maritime counter-drone has shifted toward detection and documentation first, with any further option reserved for the waters and the cases where it is permitted.
There is also the question of who is watching. On land, a control room can dedicate an operator to the airspace picture. At sea, the same officer who handles navigation and communications has to handle a drone alert. A system that demands attention will be switched off within a month. A system that stays quiet until it has something worth saying is the one that survives a real voyage.
Detection on a Rolling Deck
The sensor mix that answers these constraints is passive by preference. Our DF Series of direction-finding sensors reads a drone’s radio link without transmitting, which keeps the vessel silent in the electromagnetic sense and leaves the regulatory question for later. The fixed member of that family covers 70 MHz to 8 GHz and detects a drone at up to eight kilometers under open conditions, with direction-finding accuracy of about three degrees against a hovering target. That last detail is the one that matters at sea, because a drone that is holding position to observe a ship is exactly the case a bearing accuracy figure is meant to describe.
A bearing from a single sensor is useful but incomplete, because a bearing does not say how far away the contact is. The D5-B adds the missing dimension: a compact passive node that uses time difference of arrival across a small network to produce a position rather than a bearing. It covers 30 MHz to 6 GHz out to three kilometers, places a contact to better than ten meters, and can follow more than thirty aircraft at once with a response under two seconds. Mounted at several points on a hull, a set of nodes turns two bearings into a coordinate, which is what a bridge needs in order to say where the contact is rather than roughly which way it lies.
The third layer is visual. The VAR300 combines a visible light channel with a thermal imager and locks onto the contact the radio layer has already found, which confirms that the track is a real aircraft rather than an artifact of a crowded spectrum. Against a Mavic class target it detects at about one kilometer and tracks at about one and a half kilometers in daylight, with shorter but usable figures at night. On the water that matters more than it does on land, because a mast-level camera has a long uninterrupted view toward the horizon, and the visual record is what a master needs when the event is reported to a flag state, a port authority or an insurer.
Read together, the three layers produce what a vessel actually requires: a bearing from the passive layer, a position from the network, and a picture from the optical channel. None of them requires the ship to transmit, which is the property that makes the whole stack deployable without a licensing exercise in every port.
The Jurisdiction Problem
Maritime counter-drone is unusual in that the legal question changes with the position of the vessel. Territorial waters, contiguous zones, international straits, and the high seas each carry different rules, and those rules apply to the ship as well as to the aircraft. A master who takes a unilateral action in the wrong jurisdiction has created an exposure that outlasts the drone event by years, and may have done so on behalf of a company that would not have authorized it.
That reality pushes the architecture in a specific direction. Detection, classification, and recording are available everywhere and involve no transmission, so they form the baseline that can be switched on in any water. Response options are treated as a separate, conditional layer, enabled only where the local framework allows it and only under a defined authority on board. The practical result is a system whose first product is knowledge: what is out there, where it is, what it is doing, and a record of all three.
This is also why the recording function deserves more weight than it usually gets. A drone event at sea ends in a report to a flag state, a case file for an insurer, and sometimes a claim. The passive track with timestamps, the position history, and the optical confirmation are what turn a verbal account from a watch officer into a documented sequence that a third party can assess.
What Offshore Platforms Need Differently
Fixed offshore installations share the water but not the problems. A platform does not roll, so the sensor stability question largely disappears. It does not change jurisdiction, so the regulatory environment is known in advance and can be written into the operating plan. What it does have is a permanent watch requirement, a remote location, and a steady stream of legitimate air traffic from crew changes, supply runs, and inspection flights that must be separated from everything else.
That combination favors the same passive layers used at sea, arranged as a permanent installation rather than a portable one, with the classification layer doing the work of separating scheduled traffic from everything else. The value of a low false alarm rate is higher here than almost anywhere, because a platform that escalates every supply flight will stop trusting its own alerts within a month, and an alert that is not trusted is worse than no alert at all.
The economics point the same way. An offshore installation cannot send for help quickly, so its defense is measured in the time it buys and the confidence it creates. A detection layer that identifies a contact at range and confirms it visually gives the installation’s operator the minutes needed to move people, pause a transfer operation, or call the mainland. Those minutes are the product.
Questions a Shipowner Should Ask
Connect with us
Ready to Secure Your Low-Altitude Airspace?